

Mobile website
- News
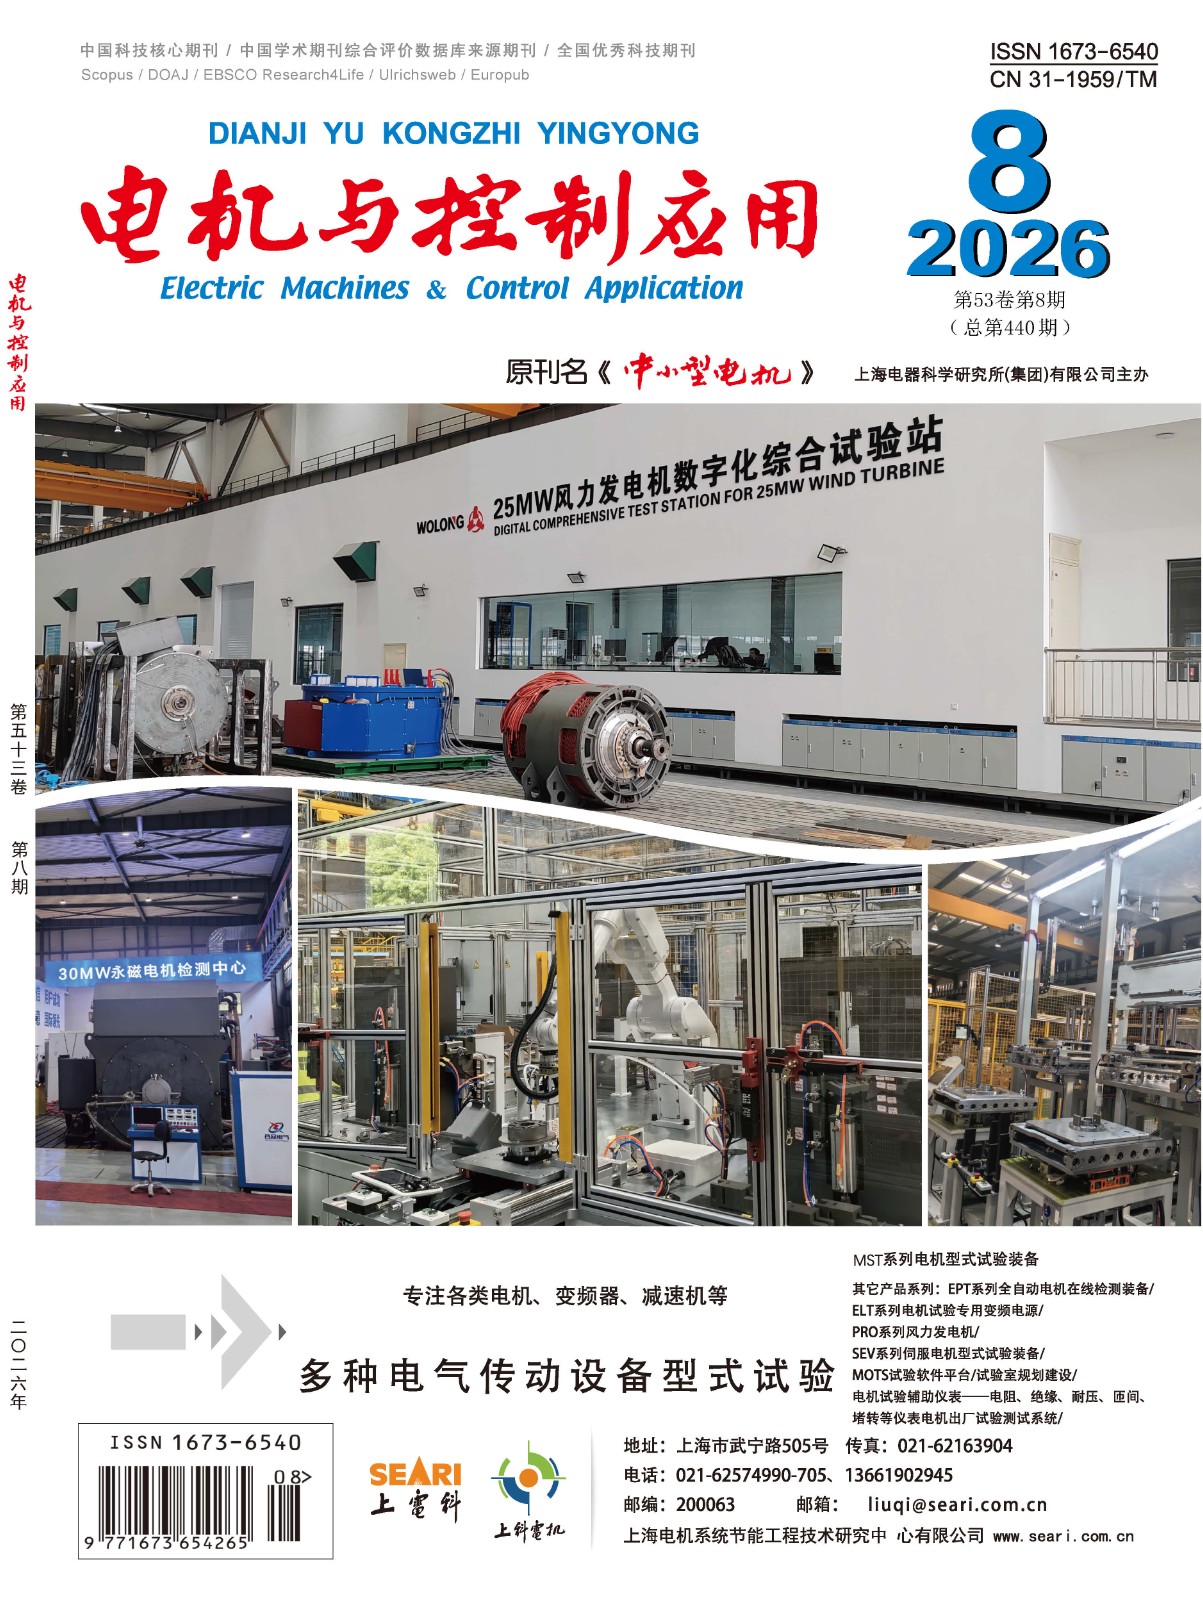
Electric Machines & Control Application (CN 31-1959/TM, ISSN 1673-6540) was founded in 1959 in title of Technical Information of Small and Medium-sized Electric Machines. The title was changed to Small and Medium-sized Electric Machines in 1977, and then changed to its current title in 2005. The journal is sponsored by Shanghai Electrical Apparatus Research Institute (Group) Co., Ltd., aims to publish cutting-edge achievements in various research fields related to the electrical science. The journal is a source journal of the Comprehensive Evaluation Database of Chinese Academic Journals, and the full text articles are included in Chinese Academic Journals (CD). It has been included in Chinese Core Journals and Key Magazine of China Technology for years. Recently, it has also been included in Scopus, EBSCO, DOAJ, EuroPub, Research4Life, ICI world of Jourmals, ICI Journal Master Lister, Japan Science and Technology Agency database (JST, Japan) and Abstract Journals (AJ, Russia). The impact factor is steadily increasing year by year. Electric Machines and Control Application is published on the 10th of each month and is publicly distributed domestically and internationally. The post issuing code is 4-199.
More
- Current Issue
- Special issue
- Archive
- Most Downloaded
- Browse by Issues
Article Search
Search by issue
Display Method:
2026,53(8):754-764, DOI: 10.12177/emca.2026.201
Abstract:
[Objective] To address the application requirements of unidirectional wireless power transfer (WPT) systems—including simplified receiver-side structure, cost-effective implementation, reliable operation, and fast load-side voltage stabilization—this study targets the decline in output stability of LCC-S WPT systems under coil misalignment, load variations, and rectifier-side input disturbances. A particle swarm optimization-based linear active disturbance rejection control (PSO-LADRC) strategy is proposed to enhance dynamic and anti-disturbance performance. [Methods] Based on the transmission characteristics of the LCC-S WPT system, a small-signal model of the secondary-side Buck converter was established. A secondary-side closed-loop controller comprising a linear extended state observer and a linear state error feedback law was constructed to realize the online estimation and compensation of the total disturbance. Furthermore, a multi-performance index objective function was formulated, and PSO was employed to optimize the key parameters of LADRC, thereby enhancing the overall control performance of the system. [Results] Experiments indicated that the output voltage was stabilized around 20 V under coil misalignments of 0, 2 cm, and 5 cm. When the reference voltage was stepped from 20 V to 15 V, the settling time of PSO-LADRC was 2 ms, which was only one-third of that of conventional LADRC. During the load step change from 15 Ω to 30 Ω, the settling time was reduced from 1.0 ms to 0.8 ms, and the overshoot was decreased from 2.2% to 1.9%. [Conclusion] The proposed PSO-LADRC strategy in this paper effectively addresses the issues of output voltage fluctuation and poor robustness in the secondary-side Buck converter of the LCC-S WPT system, providing technical support for the engineering application of high-performance WPT systems.
[Objective] To address the application requirements of unidirectional wireless power transfer (WPT) systems—including simplified receiver-side structure, cost-effective implementation, reliable operation, and fast load-side voltage stabilization—this study targets the decline in output stability of LCC-S WPT systems under coil misalignment, load variations, and rectifier-side input disturbances. A particle swarm optimization-based linear active disturbance rejection control (PSO-LADRC) strategy is proposed to enhance dynamic and anti-disturbance performance. [Methods] Based on the transmission characteristics of the LCC-S WPT system, a small-signal model of the secondary-side Buck converter was established. A secondary-side closed-loop controller comprising a linear extended state observer and a linear state error feedback law was constructed to realize the online estimation and compensation of the total disturbance. Furthermore, a multi-performance index objective function was formulated, and PSO was employed to optimize the key parameters of LADRC, thereby enhancing the overall control performance of the system. [Results] Experiments indicated that the output voltage was stabilized around 20 V under coil misalignments of 0, 2 cm, and 5 cm. When the reference voltage was stepped from 20 V to 15 V, the settling time of PSO-LADRC was 2 ms, which was only one-third of that of conventional LADRC. During the load step change from 15 Ω to 30 Ω, the settling time was reduced from 1.0 ms to 0.8 ms, and the overshoot was decreased from 2.2% to 1.9%. [Conclusion] The proposed PSO-LADRC strategy in this paper effectively addresses the issues of output voltage fluctuation and poor robustness in the secondary-side Buck converter of the LCC-S WPT system, providing technical support for the engineering application of high-performance WPT systems.
2026,53(8):765-778, DOI: 10.12177/emca.2026.203
Abstract:
[Objective] To address the issue of demodulation coefficient mismatch caused by variations in d-axis and q-axis inductances due to changing operating conditions, which degrades position observation accuracy in zero- and low-speed interior permanent magnet synchronous motor drives using high-frequency square-wave signal injection, an adaptive demodulation coefficient compensation method based on online inductance identification is proposed. [Methods] Firstly, a high-frequency square-wave injection demodulation model was established. The difference method was used to extract the high-frequency current, and the transfer mechanism of how inductance variation affects the demodulation coefficient and position observation error was derived. On this basis, a fuzzy logic cascade model reference adaptive system (FLC-MRAS) was employed to identify Ld and Lq online. The identification results were then used to reconstruct the demodulation coefficients in real time, compensating the two-phase demodulation signals. Finally, the phase error signal was fed into a phase-locked loop to achieve closed-loop estimation of rotor position and speed, thereby mitigating the impact of parameter variations on the system. [Results] Simulations were conducted on the Matlab/Simulink platform. The results indicated that under the speed step condition, the maximum identification errors of Ld and Lq using FLC-MRAS were reduced by 94.1% and 97.1%, respectively, compared to the traditional MRAS. Compared with conventional high-frequency square-wave injection, the negative peak and positive overshoot of the speed error were decreased by 43.9% and 42.4% after compensation, and the peak position error was reduced by 30.6%. Under the load step condition, the maximum identification errors of Ld and Lq were lowered by 85.7% and 95.7%, respectively; the speed drop amplitude and error peak were decreased by 70.8% and 64.8%; and the amplitude of the angular error was reduced by 60.0%. [Conclusion] The proposed method is based on FLC-MRAS online inductance identification to correct the high-frequency demodulation model in real time, which mitigates coefficient mismatch caused by inductance variations, improves the observation accuracy of speed and rotor position, and enhances system robustness under different operating conditions.
[Objective] To address the issue of demodulation coefficient mismatch caused by variations in d-axis and q-axis inductances due to changing operating conditions, which degrades position observation accuracy in zero- and low-speed interior permanent magnet synchronous motor drives using high-frequency square-wave signal injection, an adaptive demodulation coefficient compensation method based on online inductance identification is proposed. [Methods] Firstly, a high-frequency square-wave injection demodulation model was established. The difference method was used to extract the high-frequency current, and the transfer mechanism of how inductance variation affects the demodulation coefficient and position observation error was derived. On this basis, a fuzzy logic cascade model reference adaptive system (FLC-MRAS) was employed to identify Ld and Lq online. The identification results were then used to reconstruct the demodulation coefficients in real time, compensating the two-phase demodulation signals. Finally, the phase error signal was fed into a phase-locked loop to achieve closed-loop estimation of rotor position and speed, thereby mitigating the impact of parameter variations on the system. [Results] Simulations were conducted on the Matlab/Simulink platform. The results indicated that under the speed step condition, the maximum identification errors of Ld and Lq using FLC-MRAS were reduced by 94.1% and 97.1%, respectively, compared to the traditional MRAS. Compared with conventional high-frequency square-wave injection, the negative peak and positive overshoot of the speed error were decreased by 43.9% and 42.4% after compensation, and the peak position error was reduced by 30.6%. Under the load step condition, the maximum identification errors of Ld and Lq were lowered by 85.7% and 95.7%, respectively; the speed drop amplitude and error peak were decreased by 70.8% and 64.8%; and the amplitude of the angular error was reduced by 60.0%. [Conclusion] The proposed method is based on FLC-MRAS online inductance identification to correct the high-frequency demodulation model in real time, which mitigates coefficient mismatch caused by inductance variations, improves the observation accuracy of speed and rotor position, and enhances system robustness under different operating conditions.
2026,53(8):779-794, DOI: 10.12177/emca.2026.205
Abstract:
[Objective] To address the strong uncertainty in renewable energy output and load demand, complex operational constraints, and continuous decision variables in the cooperative scheduling of multi-microgrid systems, this paper proposes an economic optimization method based on an improved twin delayed deep deterministic policy gradient (TD3) algorithm. [Methods] Firstly, a three-microgrid cluster model was constructed, incorporating wind power, photovoltaic generation, micro-turbines, energy storage systems, EV charging loads, and main grid interactions. Its economic optimal dispatch process was modeled as a Markov decision process. The state space encompassed load demand, renewable generation, time-of-use electricity prices, and battery state of charge, while the action space comprised energy storage charge/discharge power, micro-turbine output, power exchange between microgrids, and interaction power with the main grid. Next, a reward function integrating normalized operating costs, environmental costs, and constraint penalty terms was designed to guide the agent in learning economical and feasible scheduling strategies. Finally, building on the original TD3 algorithm, a dual experience pool (DEP) mechanism and an adaptive exponentially decaying Gaussian exploration noise (AED-GEN) mechanism were introduced. The DEP mechanism classified experience samples into feasible solution samples and boundary exploration samples, improving sample utilization efficiency and enhancing the learning capability for constraint boundaries. Meanwhile, the AED-GEN mechanism balanced exploration during early training and convergence stability in later stages. [Results] Case studies were conducted on a three-microgrid cluster. The results demonstrated that the improved TD3 algorithm outperformed the deep deterministic policy gradient (DDPG), original TD3, and SAC algorithms in terms of convergence stability, operational economy, and scheduling security. The standard deviation of reward fluctuation in the last 100 training episodes for the improved TD3 was 1.51, representing reductions of 35.74%, 45.09%, and 54.24% compared to SAC, original TD3, and DDPG, respectively. Its total daily operating cost was 4,186.94 yuan, which was 1.38%, 6.31%, and 8.71% lower than that of SAC, original TD3, and DDPG, respectively. Meanwhile, the action limit violation rate dropped rapidly during training and gradually approached zero in the later stages. Further comparisons of the improved mechanisms verified that both the adaptive exploration noise mechanism and the dual experience pool mechanism enhanced algorithm performance. [Conclusion] By satisfying the physical operational constraints, the proposed improved TD3 method leverages the mutual support capability among multiple entities within the microgrid cluster, thereby enhancing the economic efficiency and security of the system’s collaborative scheduling.
[Objective] To address the strong uncertainty in renewable energy output and load demand, complex operational constraints, and continuous decision variables in the cooperative scheduling of multi-microgrid systems, this paper proposes an economic optimization method based on an improved twin delayed deep deterministic policy gradient (TD3) algorithm. [Methods] Firstly, a three-microgrid cluster model was constructed, incorporating wind power, photovoltaic generation, micro-turbines, energy storage systems, EV charging loads, and main grid interactions. Its economic optimal dispatch process was modeled as a Markov decision process. The state space encompassed load demand, renewable generation, time-of-use electricity prices, and battery state of charge, while the action space comprised energy storage charge/discharge power, micro-turbine output, power exchange between microgrids, and interaction power with the main grid. Next, a reward function integrating normalized operating costs, environmental costs, and constraint penalty terms was designed to guide the agent in learning economical and feasible scheduling strategies. Finally, building on the original TD3 algorithm, a dual experience pool (DEP) mechanism and an adaptive exponentially decaying Gaussian exploration noise (AED-GEN) mechanism were introduced. The DEP mechanism classified experience samples into feasible solution samples and boundary exploration samples, improving sample utilization efficiency and enhancing the learning capability for constraint boundaries. Meanwhile, the AED-GEN mechanism balanced exploration during early training and convergence stability in later stages. [Results] Case studies were conducted on a three-microgrid cluster. The results demonstrated that the improved TD3 algorithm outperformed the deep deterministic policy gradient (DDPG), original TD3, and SAC algorithms in terms of convergence stability, operational economy, and scheduling security. The standard deviation of reward fluctuation in the last 100 training episodes for the improved TD3 was 1.51, representing reductions of 35.74%, 45.09%, and 54.24% compared to SAC, original TD3, and DDPG, respectively. Its total daily operating cost was 4,186.94 yuan, which was 1.38%, 6.31%, and 8.71% lower than that of SAC, original TD3, and DDPG, respectively. Meanwhile, the action limit violation rate dropped rapidly during training and gradually approached zero in the later stages. Further comparisons of the improved mechanisms verified that both the adaptive exploration noise mechanism and the dual experience pool mechanism enhanced algorithm performance. [Conclusion] By satisfying the physical operational constraints, the proposed improved TD3 method leverages the mutual support capability among multiple entities within the microgrid cluster, thereby enhancing the economic efficiency and security of the system’s collaborative scheduling.
2026,53(8):795-806, DOI: 10.12177/emca.2026.195
Abstract:
[Objective] Although integer-slot flat-wire motors offer high power density and efficiency, they suffer from significant drawbacks, including high copper usage, substantial copper loss, and severe heat generation in the winding end regions. Therefore, this paper proposes a dual-rotor motor structure designed to reduce copper loss and enhance overall motor efficiency. [Methods] Radial concentrated winding technology was adopted for both the inner and outer stator windings, significantly reducing copper usage and associated losses at the motor ends. Meanwhile, by increasing the amount of permanent magnet material and optimizing the overall motor performance with the finite element method, the power factor and maximum output power were effectively enhanced, while the increase in iron loss was kept to a minimum. [Results] The research findings were as follows: with the flat-wire radial concentrated winding technology, the end impedance parameters (resistance/reactance), copper loss, and magnetic flux leakage were all reduced by 50% synchronously. Furthermore, under the constant-volume constraint, electromechanical co-optimization was achieved, whereby the power factor was enhanced and the maximum output power was increased. The cooling system was designed to elevate the peak efficiency, enabling the coincidence of the high-efficiency and high-power-factor regions across all operating conditions, including overload. [Conclusion] The strong consistency between simulation and theoretical calculations confirms the significant advantages of the dual-rotor motor in terms of high efficiency and high power factor, establishing a new paradigm for the design of high-density motors.
[Objective] Although integer-slot flat-wire motors offer high power density and efficiency, they suffer from significant drawbacks, including high copper usage, substantial copper loss, and severe heat generation in the winding end regions. Therefore, this paper proposes a dual-rotor motor structure designed to reduce copper loss and enhance overall motor efficiency. [Methods] Radial concentrated winding technology was adopted for both the inner and outer stator windings, significantly reducing copper usage and associated losses at the motor ends. Meanwhile, by increasing the amount of permanent magnet material and optimizing the overall motor performance with the finite element method, the power factor and maximum output power were effectively enhanced, while the increase in iron loss was kept to a minimum. [Results] The research findings were as follows: with the flat-wire radial concentrated winding technology, the end impedance parameters (resistance/reactance), copper loss, and magnetic flux leakage were all reduced by 50% synchronously. Furthermore, under the constant-volume constraint, electromechanical co-optimization was achieved, whereby the power factor was enhanced and the maximum output power was increased. The cooling system was designed to elevate the peak efficiency, enabling the coincidence of the high-efficiency and high-power-factor regions across all operating conditions, including overload. [Conclusion] The strong consistency between simulation and theoretical calculations confirms the significant advantages of the dual-rotor motor in terms of high efficiency and high power factor, establishing a new paradigm for the design of high-density motors.
2026,53(8):807-816, DOI: 10.12177/emca.2026.207
Abstract:
[Objective] To address the issue that the sensorless control process of interior permanent magnet synchronous motor (IPMSM) is susceptible to magnetic circuit saturation, which induces variations in dq-axis inductance parameters and model mismatch thereby degrading control performance, this paper employs an extended Kalman filter (EKF)-based online identification method to estimate the dq-axis inductances in real time. [Methods] The EKF algorithm was designed based on the optimal recursive estimation principle for nonlinear systems. System and measurement noises were processed through real-time updates of state prediction and the error covariance matrix. The identified inductance parameters were fed forward into the sensorless observer algorithm to achieve dynamic updating of the motor model and closed-loop feedback correction, thereby enhancing the system’s robustness against parameter variations and complex operating conditions. [Results] The experimental results indicated that with the introduction of EKF online parameter identification, favorable dynamic and steady-state performance was still maintained under low-speed loaded conditions; moreover, when a sudden load was applied in the high-speed region, the rotor position observation accuracy was enhanced by 1.5°. [Conclusion] Comparative analysis with the ordinary least squares method confirms that the EKF-based parameter identification demonstrates superior performance, effectively suppressing the impact of magnetic saturation and cross-saturation effects on position estimation.
[Objective] To address the issue that the sensorless control process of interior permanent magnet synchronous motor (IPMSM) is susceptible to magnetic circuit saturation, which induces variations in dq-axis inductance parameters and model mismatch thereby degrading control performance, this paper employs an extended Kalman filter (EKF)-based online identification method to estimate the dq-axis inductances in real time. [Methods] The EKF algorithm was designed based on the optimal recursive estimation principle for nonlinear systems. System and measurement noises were processed through real-time updates of state prediction and the error covariance matrix. The identified inductance parameters were fed forward into the sensorless observer algorithm to achieve dynamic updating of the motor model and closed-loop feedback correction, thereby enhancing the system’s robustness against parameter variations and complex operating conditions. [Results] The experimental results indicated that with the introduction of EKF online parameter identification, favorable dynamic and steady-state performance was still maintained under low-speed loaded conditions; moreover, when a sudden load was applied in the high-speed region, the rotor position observation accuracy was enhanced by 1.5°. [Conclusion] Comparative analysis with the ordinary least squares method confirms that the EKF-based parameter identification demonstrates superior performance, effectively suppressing the impact of magnetic saturation and cross-saturation effects on position estimation.
2026,53(8):817-826, DOI: 10.12177/emca.2026.197
Abstract:
[Objective] This paper proposes a fractional-order sliding mode control (FOSMC) method based on the direct power control structure, to suppress the grid-current distortion and DC voltage fluctuations of the three-phase PWM rectifier under unbalanced grid conditions. [Methods] Firstly, a dynamic model for the direct power control of the three-phase PWM rectifier under unbalanced grid conditions was established in the two-phase stationary coordinate system, eliminating the need for phase-locked loops and current loops, which simplifies the system structure. Based on this model, the control objective under unbalanced conditions was transformed into a power tracking problem by correcting the power references. Subsequently, a FOSMC power controller was constructed for the inner power loop. The introduction of the fractional-order term increased design flexibility, effectively mitigating sliding mode chattering while ensuring rapid and precise tracking of the power references. Furthermore, an extended state observer based on the inverse hyperbolic sine function was designed for the outer DC voltage loop. Leveraging its smooth and continuous characteristics, real-time estimation of DC-side load disturbances was achieved. Finally, by integrating this with the FOSMC law, the voltage outer-loop controller was formulated, guaranteeing robust DC voltage control performance even under load disturbances. [Results] The effectiveness of the proposed FOSMC method was validated by theoretical analysis and test results. [Conclusion] The proposed method achieves rapid and precise power tracking and DC voltage regulation under unbalanced grid conditions, effectively suppressing grid-current distortion and DC voltage fluctuations. It significantly enhances the system’s disturbance rejection capability, providing an effective solution for the high-performance control of three-phase PWM rectifiers in unbalanced grid scenarios.
[Objective] This paper proposes a fractional-order sliding mode control (FOSMC) method based on the direct power control structure, to suppress the grid-current distortion and DC voltage fluctuations of the three-phase PWM rectifier under unbalanced grid conditions. [Methods] Firstly, a dynamic model for the direct power control of the three-phase PWM rectifier under unbalanced grid conditions was established in the two-phase stationary coordinate system, eliminating the need for phase-locked loops and current loops, which simplifies the system structure. Based on this model, the control objective under unbalanced conditions was transformed into a power tracking problem by correcting the power references. Subsequently, a FOSMC power controller was constructed for the inner power loop. The introduction of the fractional-order term increased design flexibility, effectively mitigating sliding mode chattering while ensuring rapid and precise tracking of the power references. Furthermore, an extended state observer based on the inverse hyperbolic sine function was designed for the outer DC voltage loop. Leveraging its smooth and continuous characteristics, real-time estimation of DC-side load disturbances was achieved. Finally, by integrating this with the FOSMC law, the voltage outer-loop controller was formulated, guaranteeing robust DC voltage control performance even under load disturbances. [Results] The effectiveness of the proposed FOSMC method was validated by theoretical analysis and test results. [Conclusion] The proposed method achieves rapid and precise power tracking and DC voltage regulation under unbalanced grid conditions, effectively suppressing grid-current distortion and DC voltage fluctuations. It significantly enhances the system’s disturbance rejection capability, providing an effective solution for the high-performance control of three-phase PWM rectifiers in unbalanced grid scenarios.
2026,53(8):827-840, DOI: 10.12177/emca.2026.200
Abstract:
[Objective] To address the issues of high switching capacity requirements and significant maintenance costs in traditional bidirectional interlinking converters within active distribution networks, this paper proposes a hybrid converter consisting of a three-phase active converter (TAC) and a three-phase diode rectifier (TDR). [Methods] Firstly, the operating mechanism and control architecture of the hybrid converter were designed: when a power deficit occurred on the DC side, electrical energy flowed through the TDR to the DC side, and the TAC operated as an active filter. Conversely, when there was a power surplus on the DC side, the hybrid converter could feed energy back to the AC grid. Secondly, to address the issue of circulating currents caused by the parallel structure, which led to additional losses, the generation mechanism and influencing factors of the circulating current were analyzed in depth. Accordingly, a circulating current suppression strategy based on multi-carrier pulse width modulation (PWM) was proposed. Among the evaluated strategies, the active zero-state pulse width modulation (AZSPWM) strategy demonstrated the best performance. [Results] Test results showed that, compared with the traditional sinusoidal PWM, the proposed AZSPWM strategy effectively reduced the circulating current. Besides, the total harmonic distortion of the grid-side current was significantly reduced under both rectifier-filter and energy-regeneration modes, and the overall power loss of the system was also cut down markedly. [Conclusion] The proposed hybrid converter topology demonstrates strong feasibility, and the circulating current suppression strategy effectively addresses the inter-module circulation issue, confirming the correctness and effectiveness of the proposed AZSPWM strategy.
[Objective] To address the issues of high switching capacity requirements and significant maintenance costs in traditional bidirectional interlinking converters within active distribution networks, this paper proposes a hybrid converter consisting of a three-phase active converter (TAC) and a three-phase diode rectifier (TDR). [Methods] Firstly, the operating mechanism and control architecture of the hybrid converter were designed: when a power deficit occurred on the DC side, electrical energy flowed through the TDR to the DC side, and the TAC operated as an active filter. Conversely, when there was a power surplus on the DC side, the hybrid converter could feed energy back to the AC grid. Secondly, to address the issue of circulating currents caused by the parallel structure, which led to additional losses, the generation mechanism and influencing factors of the circulating current were analyzed in depth. Accordingly, a circulating current suppression strategy based on multi-carrier pulse width modulation (PWM) was proposed. Among the evaluated strategies, the active zero-state pulse width modulation (AZSPWM) strategy demonstrated the best performance. [Results] Test results showed that, compared with the traditional sinusoidal PWM, the proposed AZSPWM strategy effectively reduced the circulating current. Besides, the total harmonic distortion of the grid-side current was significantly reduced under both rectifier-filter and energy-regeneration modes, and the overall power loss of the system was also cut down markedly. [Conclusion] The proposed hybrid converter topology demonstrates strong feasibility, and the circulating current suppression strategy effectively addresses the inter-module circulation issue, confirming the correctness and effectiveness of the proposed AZSPWM strategy.
2026,53(8):841-851, DOI: 10.12177/emca.2026.204
Abstract:
[Objective] This paper focuses on the permanent magnet synchronous generator used in new energy vehicle range extenders. It addresses the issues of mechanical chattering caused by engine torque ripple and current distortion resulting from air-gap magnetic field distortion and inverter nonlinearities. The aim is to optimize motor control algorithms to enhance system robustness, thereby effectively suppressing vibration interference from the engine and torque ripple generated by the motor itself. [Methods] To improve the robustness of the speed outer loop and suppress chattering caused by engine torque ripple, the traditional PI controller was replaced by an improved sliding mode compensation controller. Meanwhile, to reduce the torque ripple inherent to the motor, a harmonic injection algorithm was introduced to specifically suppress the 5th and 7th current harmonics, thereby effectively mitigating the impact of harmonic currents. [Results] Simulation and experimental results indicated that significant improvements were achieved in both disturbance rejection performance and current quality by the proposed strategy. Under the condition of 500 r/min and a 120 N·m step load, the peak speed overshoot was reduced from 538 r/min to 532 r/min, compared with the traditional PI controller. Meanwhile, the 5th and 7th current harmonics were almost completely eliminated by the harmonic injection algorithm. The key harmonic current components, id5th, id7th, and iq7th, were all suppressed to 0, verifying the effectiveness of the proposed strategy. [Conclusion] The improved sliding mode controller enhances system robustness, enabling faster post-disturbance speed recovery and smaller fluctuations. Concurrently, the harmonic injection algorithm effectively suppresses current harmonics caused by inverter nonlinearities and motor magnetic field distortion, improving current quality. The combination of both achieves superior steady-state performance.
[Objective] This paper focuses on the permanent magnet synchronous generator used in new energy vehicle range extenders. It addresses the issues of mechanical chattering caused by engine torque ripple and current distortion resulting from air-gap magnetic field distortion and inverter nonlinearities. The aim is to optimize motor control algorithms to enhance system robustness, thereby effectively suppressing vibration interference from the engine and torque ripple generated by the motor itself. [Methods] To improve the robustness of the speed outer loop and suppress chattering caused by engine torque ripple, the traditional PI controller was replaced by an improved sliding mode compensation controller. Meanwhile, to reduce the torque ripple inherent to the motor, a harmonic injection algorithm was introduced to specifically suppress the 5th and 7th current harmonics, thereby effectively mitigating the impact of harmonic currents. [Results] Simulation and experimental results indicated that significant improvements were achieved in both disturbance rejection performance and current quality by the proposed strategy. Under the condition of 500 r/min and a 120 N·m step load, the peak speed overshoot was reduced from 538 r/min to 532 r/min, compared with the traditional PI controller. Meanwhile, the 5th and 7th current harmonics were almost completely eliminated by the harmonic injection algorithm. The key harmonic current components, id5th, id7th, and iq7th, were all suppressed to 0, verifying the effectiveness of the proposed strategy. [Conclusion] The improved sliding mode controller enhances system robustness, enabling faster post-disturbance speed recovery and smaller fluctuations. Concurrently, the harmonic injection algorithm effectively suppresses current harmonics caused by inverter nonlinearities and motor magnetic field distortion, improving current quality. The combination of both achieves superior steady-state performance.
2026,53(8):852-861, DOI: 10.12177/emca.2026.196
Abstract:
[Objective] To address the challenge that controllable excitation linear synchronous motor (CELSM) faces in simultaneously achieving high-precision trajectory tracking, strong disturbance rejection, and smooth control input under complex sudden load disturbances, an improved variable-gain super-twisting sliding mode control (IVG-STSMC) strategy is proposed. This strategy aims to enhance the system’s dynamic response quality and suppress the high-frequency chattering inherent in conventional sliding mode control. [Methods] Firstly, a mathematical model of the CELSM in the d-q coordinate system was established. On this basis, a continuous Softsign function was employed to replace the traditional sign function, and a variable-gain adaptive adjustment mechanism based on state errors was introduced to construct the VG-STSMC controller. This step was taken to alleviate the conflict between chattering and convergence speed caused by the fixed gain and discontinuous switching of the sign function. Furthermore, a nonlinear disturbance observer (NDOB) without acceleration measurement was incorporated into the VG-STSMC to estimate the lumped disturbance online. Finally, a composite IVG-STSMC control framework was established through feedforward compensation. [Results] Simulation results demonstrated that under the condition of sinusoidal reference trajectory tracking with an amplitude of 1 mm and a frequency of 0.5 Hz, IVG-STSMC outperformed both proportional integral control and conventional SMC overall in terms of tracking accuracy, speed smoothness, and current chattering suppression. Under the compound working condition where a 50 N step load was applied at t=1.0 s and removed at t=2.5 s, a 51.8% reduction in maximum tracking error was achieved by IVG-STSMC compared to VG-STSMC, and a 65.5% reduction in peak error was recorded at the exact moment the disturbance was introduced. Furthermore, the smoothness of the speed and q-axis current responses during disturbance switching was further improved by IVG-STSMC. [Conclusion] The proposed strategy effectively coordinates trajectory tracking accuracy, disturbance rejection capability, and control input smoothness of the CELSM feed system under complex load disturbances, verifying the effectiveness of the synergistic mechanism between variable-gain higher-order sliding mode regulation and disturbance feedforward compensation.
[Objective] To address the challenge that controllable excitation linear synchronous motor (CELSM) faces in simultaneously achieving high-precision trajectory tracking, strong disturbance rejection, and smooth control input under complex sudden load disturbances, an improved variable-gain super-twisting sliding mode control (IVG-STSMC) strategy is proposed. This strategy aims to enhance the system’s dynamic response quality and suppress the high-frequency chattering inherent in conventional sliding mode control. [Methods] Firstly, a mathematical model of the CELSM in the d-q coordinate system was established. On this basis, a continuous Softsign function was employed to replace the traditional sign function, and a variable-gain adaptive adjustment mechanism based on state errors was introduced to construct the VG-STSMC controller. This step was taken to alleviate the conflict between chattering and convergence speed caused by the fixed gain and discontinuous switching of the sign function. Furthermore, a nonlinear disturbance observer (NDOB) without acceleration measurement was incorporated into the VG-STSMC to estimate the lumped disturbance online. Finally, a composite IVG-STSMC control framework was established through feedforward compensation. [Results] Simulation results demonstrated that under the condition of sinusoidal reference trajectory tracking with an amplitude of 1 mm and a frequency of 0.5 Hz, IVG-STSMC outperformed both proportional integral control and conventional SMC overall in terms of tracking accuracy, speed smoothness, and current chattering suppression. Under the compound working condition where a 50 N step load was applied at t=1.0 s and removed at t=2.5 s, a 51.8% reduction in maximum tracking error was achieved by IVG-STSMC compared to VG-STSMC, and a 65.5% reduction in peak error was recorded at the exact moment the disturbance was introduced. Furthermore, the smoothness of the speed and q-axis current responses during disturbance switching was further improved by IVG-STSMC. [Conclusion] The proposed strategy effectively coordinates trajectory tracking accuracy, disturbance rejection capability, and control input smoothness of the CELSM feed system under complex load disturbances, verifying the effectiveness of the synergistic mechanism between variable-gain higher-order sliding mode regulation and disturbance feedforward compensation.
2026,53(8):862-872, DOI: 10.12177/emca.2026.199
Abstract:
[Objective] To address the issue of transient reverse power and secondary power oscillations caused by a lack of dynamic damping in traditional fixed-parameter virtual synchronous generators (VSG) during ship-to-shore power grid connection and load transfer processes, this paper proposes an active reverse power suppression strategy based on inertia and damping adaptation. [Methods] An adaptive parameter mechanism driven by transient energy variation was established. An event-triggered mechanism based on active power deviation and virtual frequency over-limit was constructed to drive the time-domain dynamic evolution of VSG virtual parameters. In the initial stage of reverse power impact, the damping was significantly increased following a cosine envelope law to strongly absorb unbalanced transient energy. During the steady-state recovery period, the moment of inertia was bidirectionally adjusted according to the disturbance polarity: it was reduced to accelerate the dynamic response during the grid-connected climbing stage, and it was increased to suppress frequency fluctuations during the sudden load rejection stage. [Results] It was demonstrated via Matlab/Simulink simulations that under strong disturbance conditions such as grid-connection and extreme load rejection, the proposed adaptive VSG control strategy strictly limited the reverse power drop depth within the safety threshold, effectively eliminated the secondary underdamped oscillation of active power, and precisely clamped the transient frequency deviation within the safe range. [Conclusion] The adaptive VSG control strategy proposed in this paper overcomes the limitations of traditional VSG, which struggle to balance impact resistance and fast recovery. It achieves safe and flexible interconnection between the shore and ship power grids from the underlying control dimension, and significantly improves the grid-connection robustness of large-capacity variable-frequency shore power systems under extreme operating conditions.
[Objective] To address the issue of transient reverse power and secondary power oscillations caused by a lack of dynamic damping in traditional fixed-parameter virtual synchronous generators (VSG) during ship-to-shore power grid connection and load transfer processes, this paper proposes an active reverse power suppression strategy based on inertia and damping adaptation. [Methods] An adaptive parameter mechanism driven by transient energy variation was established. An event-triggered mechanism based on active power deviation and virtual frequency over-limit was constructed to drive the time-domain dynamic evolution of VSG virtual parameters. In the initial stage of reverse power impact, the damping was significantly increased following a cosine envelope law to strongly absorb unbalanced transient energy. During the steady-state recovery period, the moment of inertia was bidirectionally adjusted according to the disturbance polarity: it was reduced to accelerate the dynamic response during the grid-connected climbing stage, and it was increased to suppress frequency fluctuations during the sudden load rejection stage. [Results] It was demonstrated via Matlab/Simulink simulations that under strong disturbance conditions such as grid-connection and extreme load rejection, the proposed adaptive VSG control strategy strictly limited the reverse power drop depth within the safety threshold, effectively eliminated the secondary underdamped oscillation of active power, and precisely clamped the transient frequency deviation within the safe range. [Conclusion] The adaptive VSG control strategy proposed in this paper overcomes the limitations of traditional VSG, which struggle to balance impact resistance and fast recovery. It achieves safe and flexible interconnection between the shore and ship power grids from the underlying control dimension, and significantly improves the grid-connection robustness of large-capacity variable-frequency shore power systems under extreme operating conditions.
Article Search
Search by issue


Article Search
Search by issue
Display Method:
Abstract:
The impact of largescale access of wind farms on the transient stability of power grids could not be ignored. Taking the extended twomachine system with doublyfed wind turbines as an example, the equivalent model of doublyfed induction generator was established, and the twomachine system could be equivalent to a singlemachine infinity system. Based on the law of equal area, the analytic formula of critical clearing angle of the system was deduced in detail after wind power accessed. The analytic formula was used to quantitatively analyze the variation trends of the critical clearing angle with wind power ratio, wind turbine grid connection position, fault location and load access position. The influence laws of the above four factors on the stability of transient power angle were summarized. The simulation models of the extended twomachine system with doublyfed induction generator was established in BPA and FASTEST, and the accuracy of the theoretical analysis was verified.
The impact of largescale access of wind farms on the transient stability of power grids could not be ignored. Taking the extended twomachine system with doublyfed wind turbines as an example, the equivalent model of doublyfed induction generator was established, and the twomachine system could be equivalent to a singlemachine infinity system. Based on the law of equal area, the analytic formula of critical clearing angle of the system was deduced in detail after wind power accessed. The analytic formula was used to quantitatively analyze the variation trends of the critical clearing angle with wind power ratio, wind turbine grid connection position, fault location and load access position. The influence laws of the above four factors on the stability of transient power angle were summarized. The simulation models of the extended twomachine system with doublyfed induction generator was established in BPA and FASTEST, and the accuracy of the theoretical analysis was verified.
Abstract:
Multimotor synchronous and coordinate system was widely used in the field of motor control. The control strategy played a important role in the performance of multimotor synchronization system. Domestic and foreign scholars had conducted deep research, who aimed at the problem of multimotor synchronization.They put forward a variety of synchronization control strategies. The control strategies proposed at home and abroad were reviewed. The accuracy of tracking, robustness and capacity of antiload of the control object were analyzed. The new prospect of multimotor synchronization control was proposed.
Multimotor synchronous and coordinate system was widely used in the field of motor control. The control strategy played a important role in the performance of multimotor synchronization system. Domestic and foreign scholars had conducted deep research, who aimed at the problem of multimotor synchronization.They put forward a variety of synchronization control strategies. The control strategies proposed at home and abroad were reviewed. The accuracy of tracking, robustness and capacity of antiload of the control object were analyzed. The new prospect of multimotor synchronization control was proposed.
Abstract:
Inwheel motor drive technology represents an essential development direction in new energy vehicle drive system. The technical requirements and drive form were introduced. The technical requirements and drive form of inwheel motor drive were summarized. Current research situation of inwheel motor drive technology was compared and analyzed briefly. The key technique problems of inwheel motor technology were proposed. The essential technologies in descreasing unsprung mass, restraining vertical vibration effect and reducing torque ripple of inwheel motor were discussed, which were supposed to be solved urgently. The development trend of inwheel motor drive technology was predicted.
Inwheel motor drive technology represents an essential development direction in new energy vehicle drive system. The technical requirements and drive form were introduced. The technical requirements and drive form of inwheel motor drive were summarized. Current research situation of inwheel motor drive technology was compared and analyzed briefly. The key technique problems of inwheel motor technology were proposed. The essential technologies in descreasing unsprung mass, restraining vertical vibration effect and reducing torque ripple of inwheel motor were discussed, which were supposed to be solved urgently. The development trend of inwheel motor drive technology was predicted.
2024,51(9):70-79, DOI: 10.12177/emca.2024.090
Abstract:
To address the issue of high torque ripple in permanent magnet assisted synchronous reluctance motor (PMA-SynRM), a multi-objective optimization design method based on the non-dominated sorting genetic algorithm II (NSGA-II) was proposed. First, the basic structure and working principle of the PMA-SynRM were introduced. Next, the rotor structure of the PMA-SynRM was improved by constructing air barriers and designing asymmetric auxiliary slots. Then, sensitivity analysis was conducted to identify the parameters that had the most significant impact on the optimization objectives of the PMA-SynRM, and multi-objective optimization was performed using NSGA-II. The optimal topology was selected from the generated Pareto front. Finally, the torque performance of the optimized motor was compared with that of the initial motor using finite element analysis software. Simulation results showed that the performance of the PMA-SynRM optimized through NSGA-II was significantly improved.
To address the issue of high torque ripple in permanent magnet assisted synchronous reluctance motor (PMA-SynRM), a multi-objective optimization design method based on the non-dominated sorting genetic algorithm II (NSGA-II) was proposed. First, the basic structure and working principle of the PMA-SynRM were introduced. Next, the rotor structure of the PMA-SynRM was improved by constructing air barriers and designing asymmetric auxiliary slots. Then, sensitivity analysis was conducted to identify the parameters that had the most significant impact on the optimization objectives of the PMA-SynRM, and multi-objective optimization was performed using NSGA-II. The optimal topology was selected from the generated Pareto front. Finally, the torque performance of the optimized motor was compared with that of the initial motor using finite element analysis software. Simulation results showed that the performance of the PMA-SynRM optimized through NSGA-II was significantly improved.
Contact Us
Download Center
You are thevisitor
沪ICP备16038578号-3
Electric Machines & Control Application ® 2026
Supported by:Beijing E-Tiller Technology Development Co., Ltd.
沪ICP备16038578号-3
Electric Machines & Control Application ® 2026
Supported by:Beijing E-Tiller Technology Development Co., Ltd.
